

Discover the AGV
Motorized and steerable wheels are at the heart of autonomous vehicles designed for agriculture and intralogistics. These systems require high-torque, reliable, and energy-efficient motors to ensure precise maneuverability and consistent performance in demanding environments. Whether navigating uneven terrain in a vineyard or optimizing material flow in a warehouse, robust wheel drive solutions enable autonomy, productivity, and sustainability.
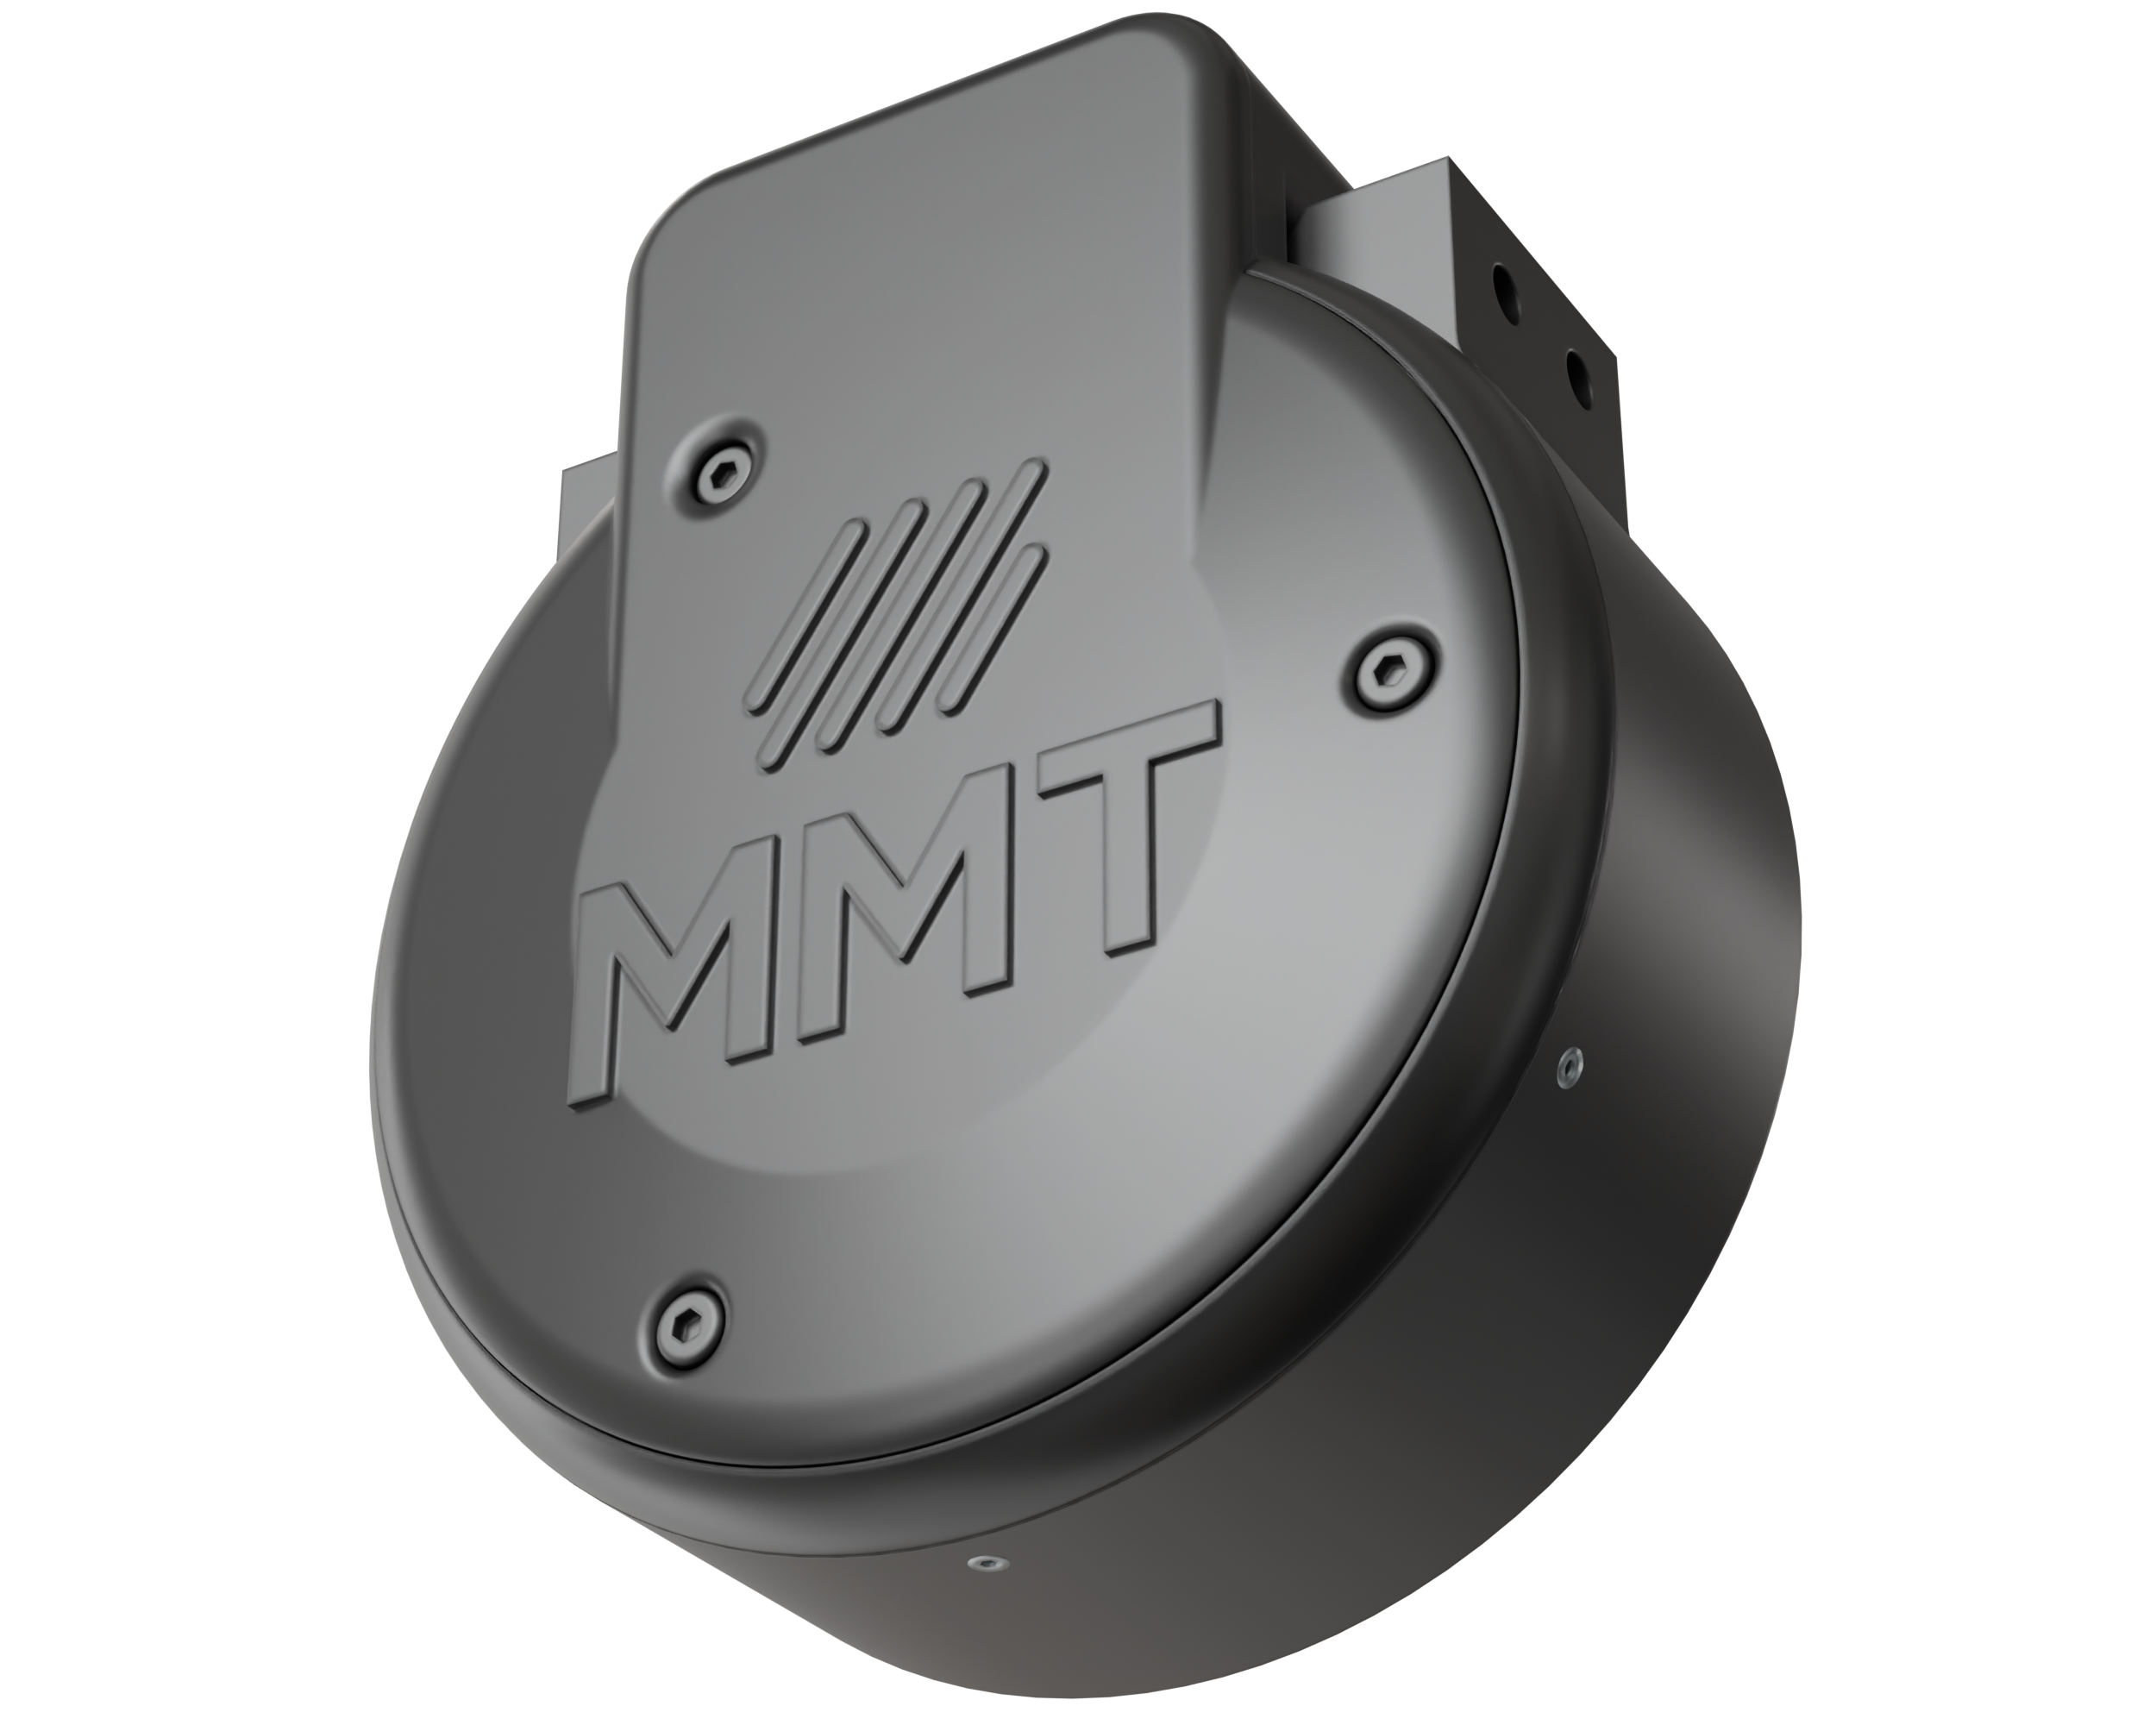
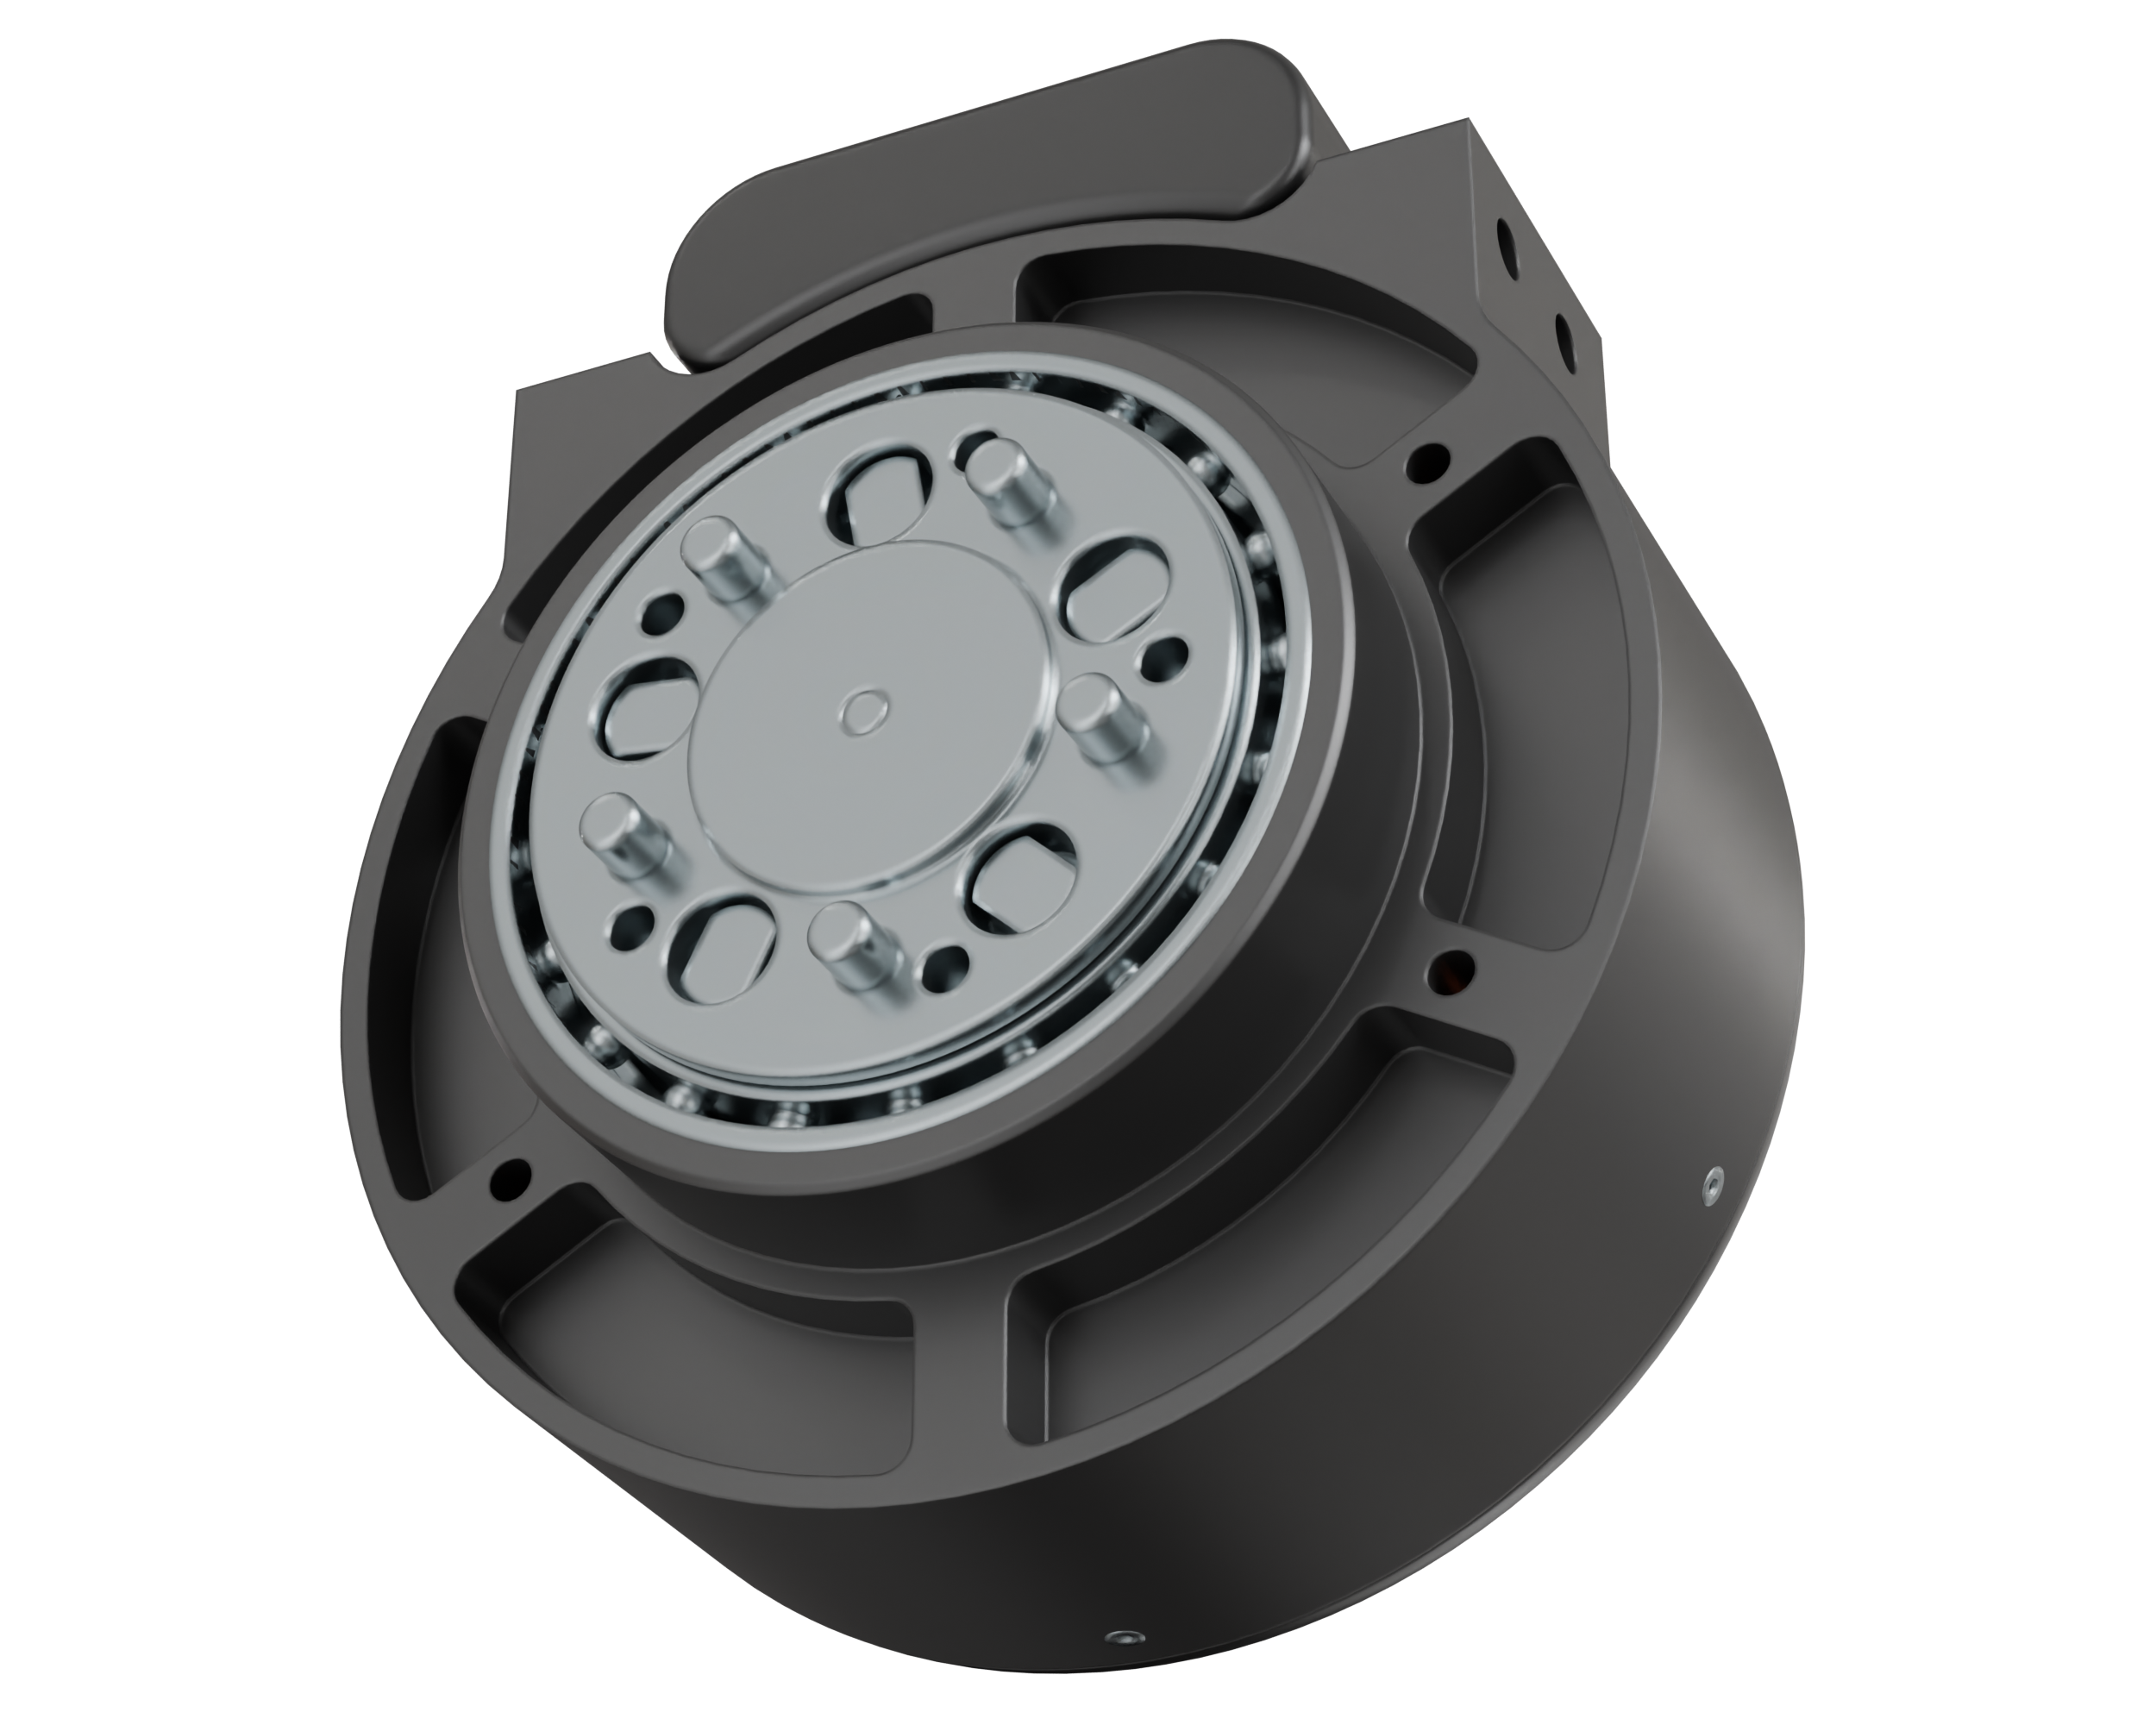
At MMT, we believe that simplicity is the ultimate sophistication, echoing Leonardo da Vinci’s timeless principle. Our integrated gear reducers are designed with this philosophy in mind: fewer components mean not only a more compact system but also enhanced reliability. Based on cycloidal gear technology combined with conventional tooth profiles and differential principles, our design minimizes the need for multiple guiding elements. Each reduction ratio is carefully selected in synergy with motor sizing to optimize the complete wheel assembly—delivering superior efficiency and space-saving performance.
Our motors work in perfect harmony to serve the entire system. Each unit integrates its own control electronics and sensors, ensuring smooth, fast, and safe movements. This embedded intelligence allows precise coordination between wheels, delivering optimal performance for autonomous applications in agriculture and intralogistics. Moreover, we bring proven expertise in safety-critical electronics with continuity of operation. Our advanced control strategies enable degraded operating modes, ensuring that even in fault conditions, the system remains functional and secure.
Our mastery of all the building blocks of a motorized wheel for autonomous vehicles also allows us to integrate advanced features such as locks to keep the vehicle securely in place without energy consumption, and even wireless power transmission. These innovations enhance functionality, safety, and flexibility, making our solutions ideal for demanding environments.